
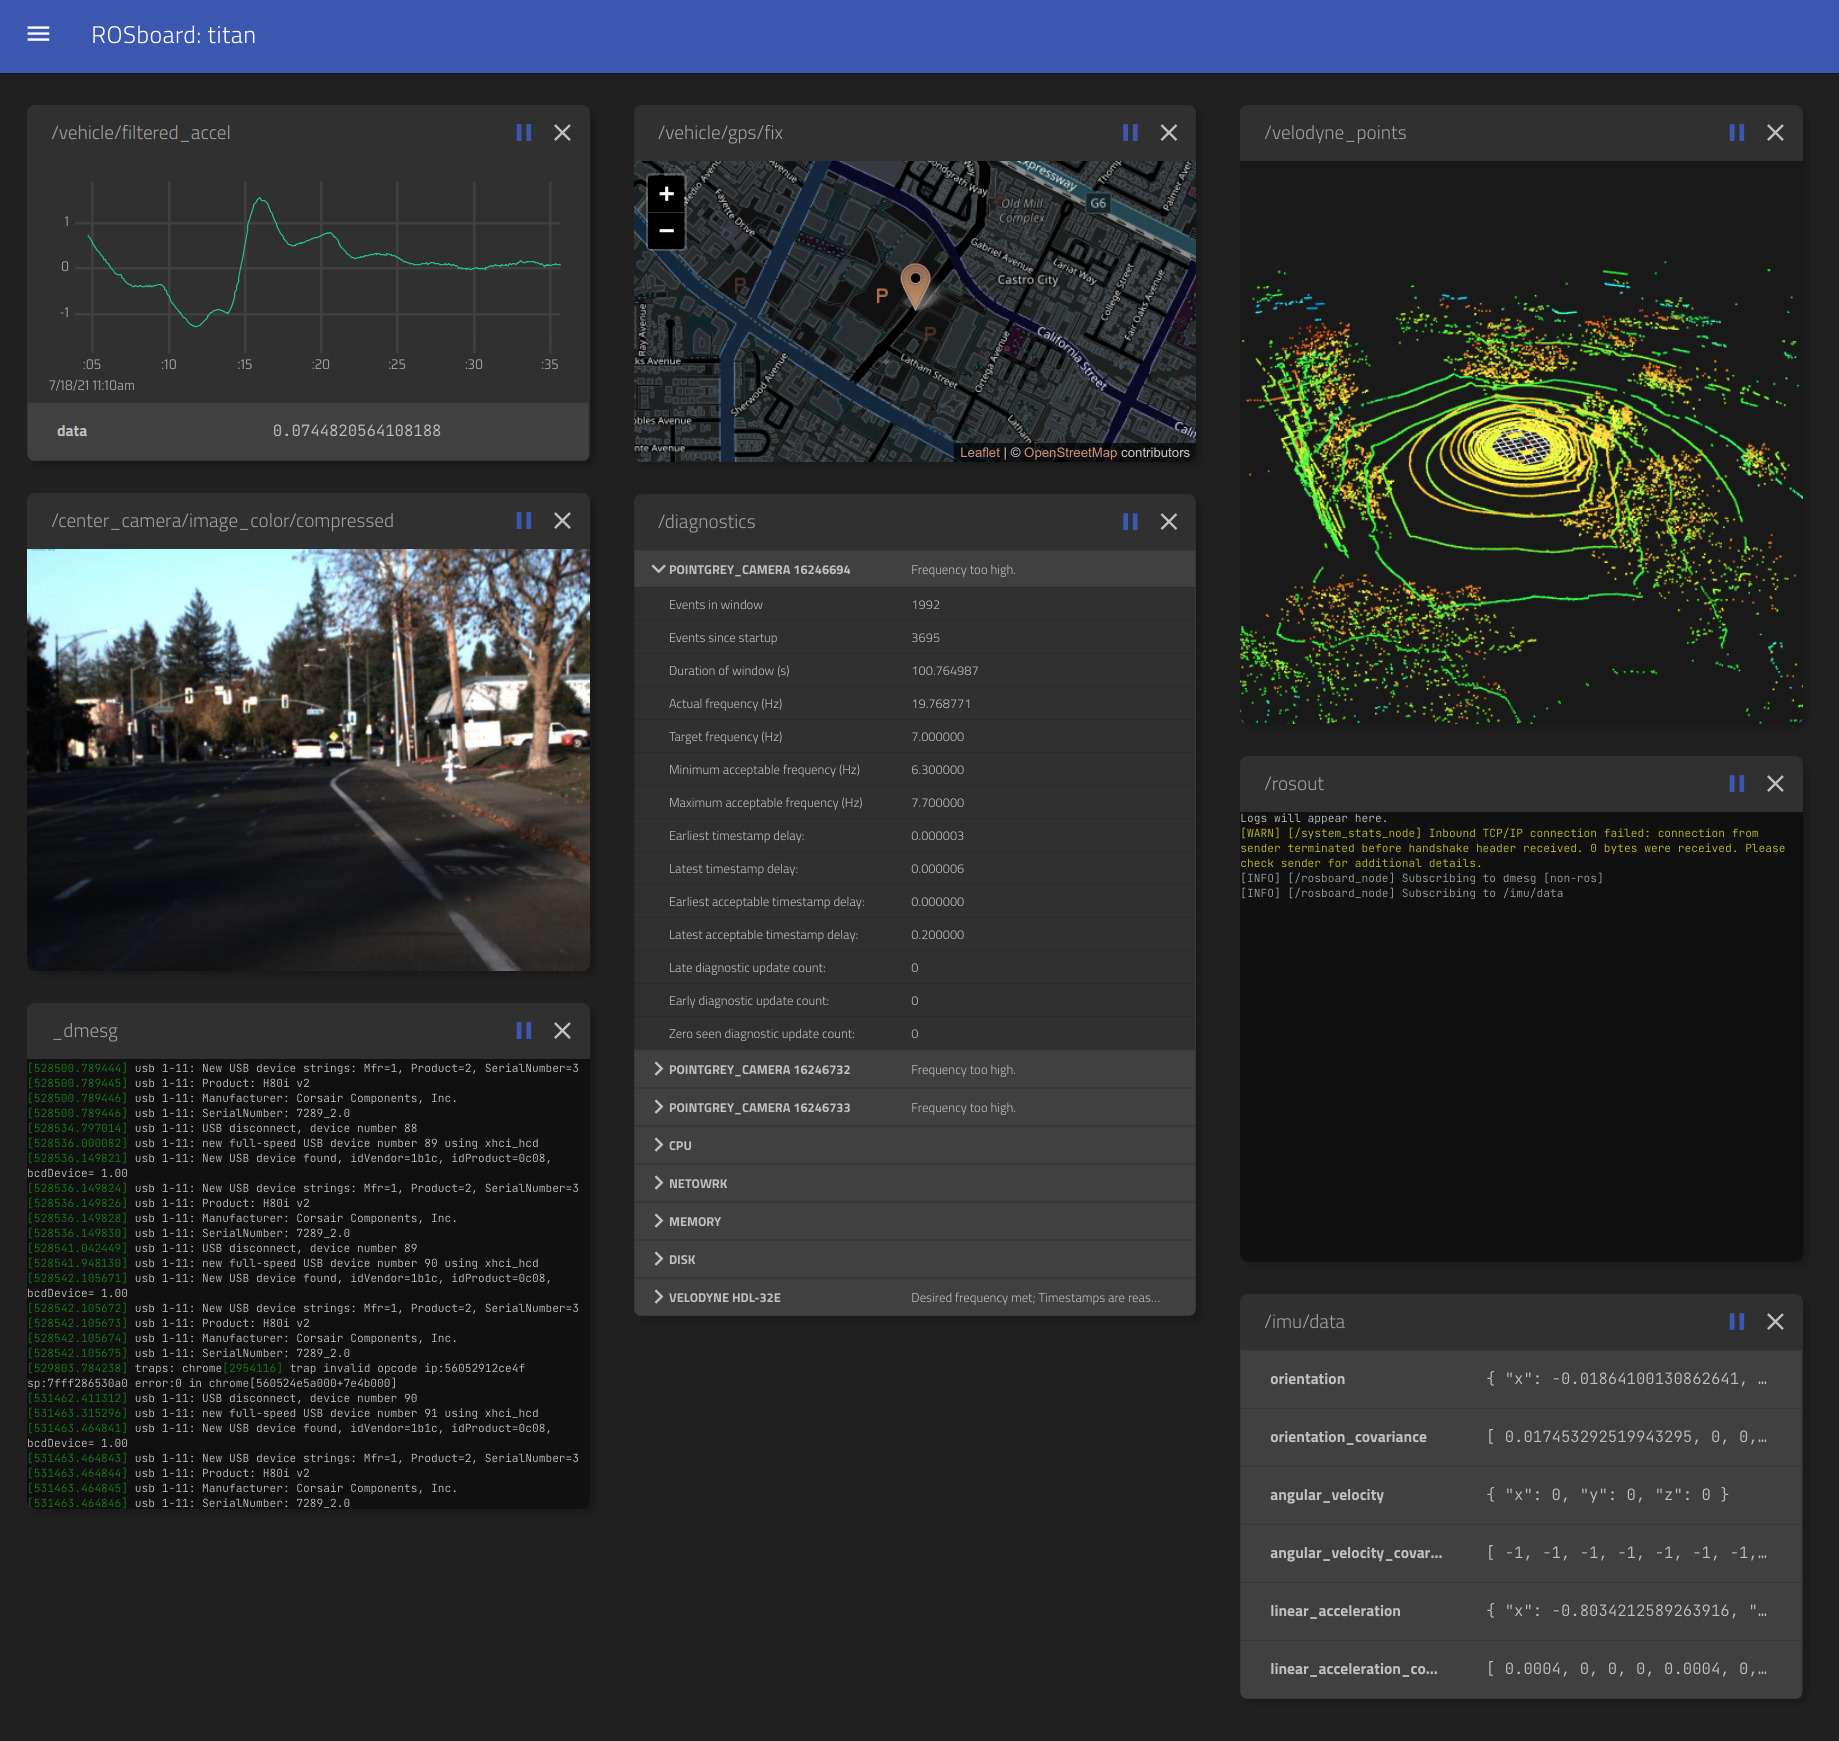
ROSboard is a lightweight web dashboard for visualizing ROS topics directly from a robot. Running the ROS node starts a web server, after which the dashboard can be opened from a desktop, tablet or phone on the same network. Its design is deliberately simple and resource-conscious, making it suitable for robots where a full desktop visualization environment would be inconvenient or unnecessarily heavy.
ROSboard is especially useful for field diagnostics, telemetry and quickly checking sensor output without setting up a separate operator workstation. It can also be run on a desktop when examining recorded robot data.
This is free and open source software.
Key Features
- Presents ROS topics as responsive cards in a mobile-friendly browser interface.
- Includes visualizers for common sensor and message types.
- Displays images, point clouds, GPS information, diagnostics and time-series data.
- Compresses large image and point-cloud messages before transmitting them to the browser.
- Uses robot-side timestamps when forwarding messages over its WebSocket bridge.
- Provides 3D visualizations through WebGL-based components.
- Uses Leaflet for geographical data such as satellite-position messages.
- Can visualize recorded ROS bag data.
- Requires very few resources while the dashboard is not being actively used.
- Allows custom message visualizers to be added with a JavaScript viewer file.
- Avoids giving the browser unrestricted access to the complete ROS system.
Website: github.com/dheera/rosboard
Support:
Developer: Dheera Venkatraman
License: BSD 3-Clause “New” or “Revised” License
ROSboard is written in JavaScript and Python. Learn JavaScript with our recommended free books and free tutorials. Learn Python with our recommended free books and free tutorials.
Related Software
| Robotics Software | |
|---|---|
| NASA Vision Workbench | Image processing in the context of machine vision |
| DART | Dynamic Animation and Robotics Toolkit |
| Gazebo Sim | Robot simulation made easy |
| AprilTag | Visual fiducial system popular for robotics research |
| Webots | Multi-platform desktop application used to simulate robots |
| ROS | Software framework for building robot applications |
| ARGoS | Physics-based simulator designed to simulate robot swarms |
| RTAB-Map | Graph-based SLAM software for 3D mapping and navigation |
| MoveIt | Robotic manipulation platform for ROS 2 |
| OpenRTM-aist | Component-oriented development of robot systems |
| ROSboard | Lightweight web dashboard for visualizing ROS data |
| Vizanti | Web-based visualizer and mission planner for ROS robots |
| Choreonoid | Integrated graphical framework for robotics development |
Read our verdict in the software roundup.
 Explore our carefully curated directory of recommended free and open source software, covering every major software category. The directory forms part of our extensive collection of articles for Linux enthusiasts. It includes hundreds of detailed reviews, together with free and open source alternatives to proprietary software from companies such as Google, Microsoft, Apple, Adobe, IBM, Cisco, Oracle, and Autodesk. LinuxLinks also covers interesting projects worth exploring, Linux-compatible hardware, free programming books and tutorials, and much more. Know a useful free and open source Linux application that we haven’t covered? Tell us about it using our submission form. |
Please read our Comment Policy before commenting.