
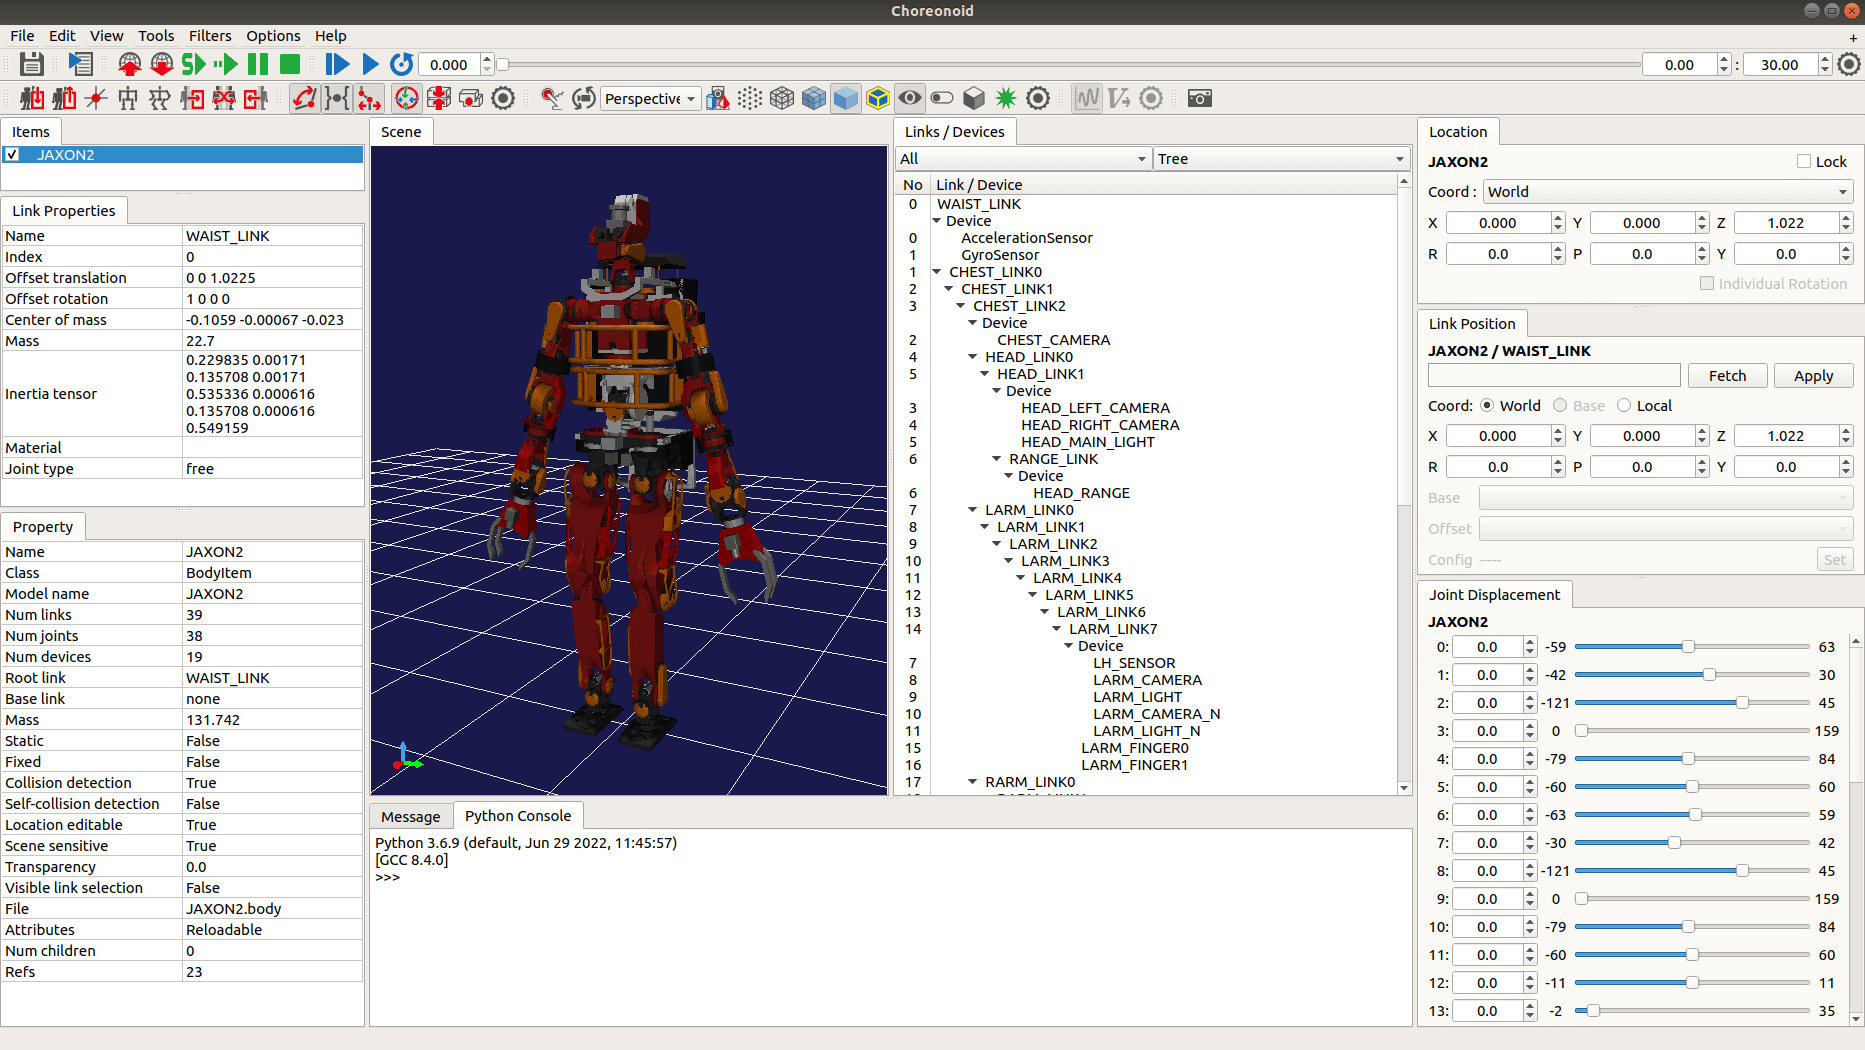
Choreonoid is an integrated graphical framework for robot development. It combines model inspection, simulation and motion work inside one extensible desktop application rather than splitting these tasks across several unrelated tools.
The framework is designed to remain lightweight while providing a common environment for researchers, developers and engineers working with robot models and control systems. Its plugin architecture is central to the design, allowing specialised functionality to be added without rebuilding the application around a particular robot or research project.
Because visualization, simulation and motion editing share the same environment, developers can examine a model, test its behaviour and refine motions without continually switching applications. Choreonoid has been used for projects spanning academic research, industrial robotics and entertainment, with a particularly long history in humanoid robotics.
This is free and open source software.
Key Features
- Visualizes robot and environment models in an interactive 3D interface.
- Provides GUI tools for editing model files.
- Checks robot models for self-collisions.
- Calculates forward and inverse kinematics.
- Displays camera images, point clouds and force/torque sensor data.
- Includes dynamics simulation for robots interacting with their environments.
- Uses a contact-oriented default physics engine suited to demanding robot simulations.
- Provides tools for choreographing and editing robot motions.
- Lets motion editing make use of the same visualization and dynamics facilities.
- Supports plugins for adding project-specific tools and functionality.
- Can be extended with resources supplied by Choreonoid and third parties.
- Provides integration with ROS.
Website: github.com/choreonoid/choreonoid
Support:
Developer: Choreonoid Inc.
License: MIT License
Choreonoid is written in C++. Learn C++ with our recommended free books and free tutorials.
Related Software
| Robotics Software | |
|---|---|
| NASA Vision Workbench | Image processing in the context of machine vision |
| DART | Dynamic Animation and Robotics Toolkit |
| Gazebo Sim | Robot simulation made easy |
| AprilTag | Visual fiducial system popular for robotics research |
| Webots | Multi-platform desktop application used to simulate robots |
| ROS | Software framework for building robot applications |
| ARGoS | Physics-based simulator designed to simulate robot swarms |
| RTAB-Map | Graph-based SLAM software for 3D mapping and navigation |
| MoveIt | Robotic manipulation platform for ROS 2 |
| OpenRTM-aist | Component-oriented development of robot systems |
| ROSboard | Lightweight web dashboard for visualizing ROS data |
| Vizanti | Web-based visualizer and mission planner for ROS robots |
| Choreonoid | Integrated graphical framework for robotics development |
Read our verdict in the software roundup.
 LinuxLinks helps you discover the best free and open source software for Linux. Explore our extensive collection of recommended applications, including alternatives to popular proprietary software. We also publish software reviews, Linux tutorials, hardware reviews, free programming books and articles covering the wider open source community. Browse our Linux resources to discover more. Know a useful free and open source Linux application we haven't covered? Suggest a program for inclusion. Has your software been featured on LinuxLinks? Display one of our Featured on LinuxLinks badges on your website or GitHub README. |
Please read our Comment Policy before commenting.